Sensor Rig
The test car with its roof sensors: Ouster and Robosense RSP128 LiDARs, 8 Lucid cameras and the
32 microphones on an aluminium frame. Positions come from the car's Autoware description
(prius_sensor_kit_description). Drag to rotate, scroll to zoom.
Body: 3rd-generation Prius (XW30, as the test car) or the 4th-generation Autoware model. Cameras: Physical layout places them where they sit on the rig; Autoware calibration uses the calibrated positions.
Why two variants. The camera angles in the calibration are clean (45° steps), but the positions are not physically
possible: camera0 sits 5 cm inside the roof, the rear-facing camera4 is 30 cm ahead of the front-facing camera0, and all eight
cameras lie within 0.5 m of the LiDAR although the frame they are mounted on spans 1.1 m × 1.37 m. This looks like a
LiDAR-to-camera calibration where the rotations converged and the translations did not. The physical layout takes the positions
from the photos of the rig (exact relative to the plates, a few centimetres of uncertainty for how far each camera sticks out).
Sensor positions (base_link, metres)
| Sensor | x | y | z | Faces | Height above roof | Distance from LiDAR |
|---|
Renders
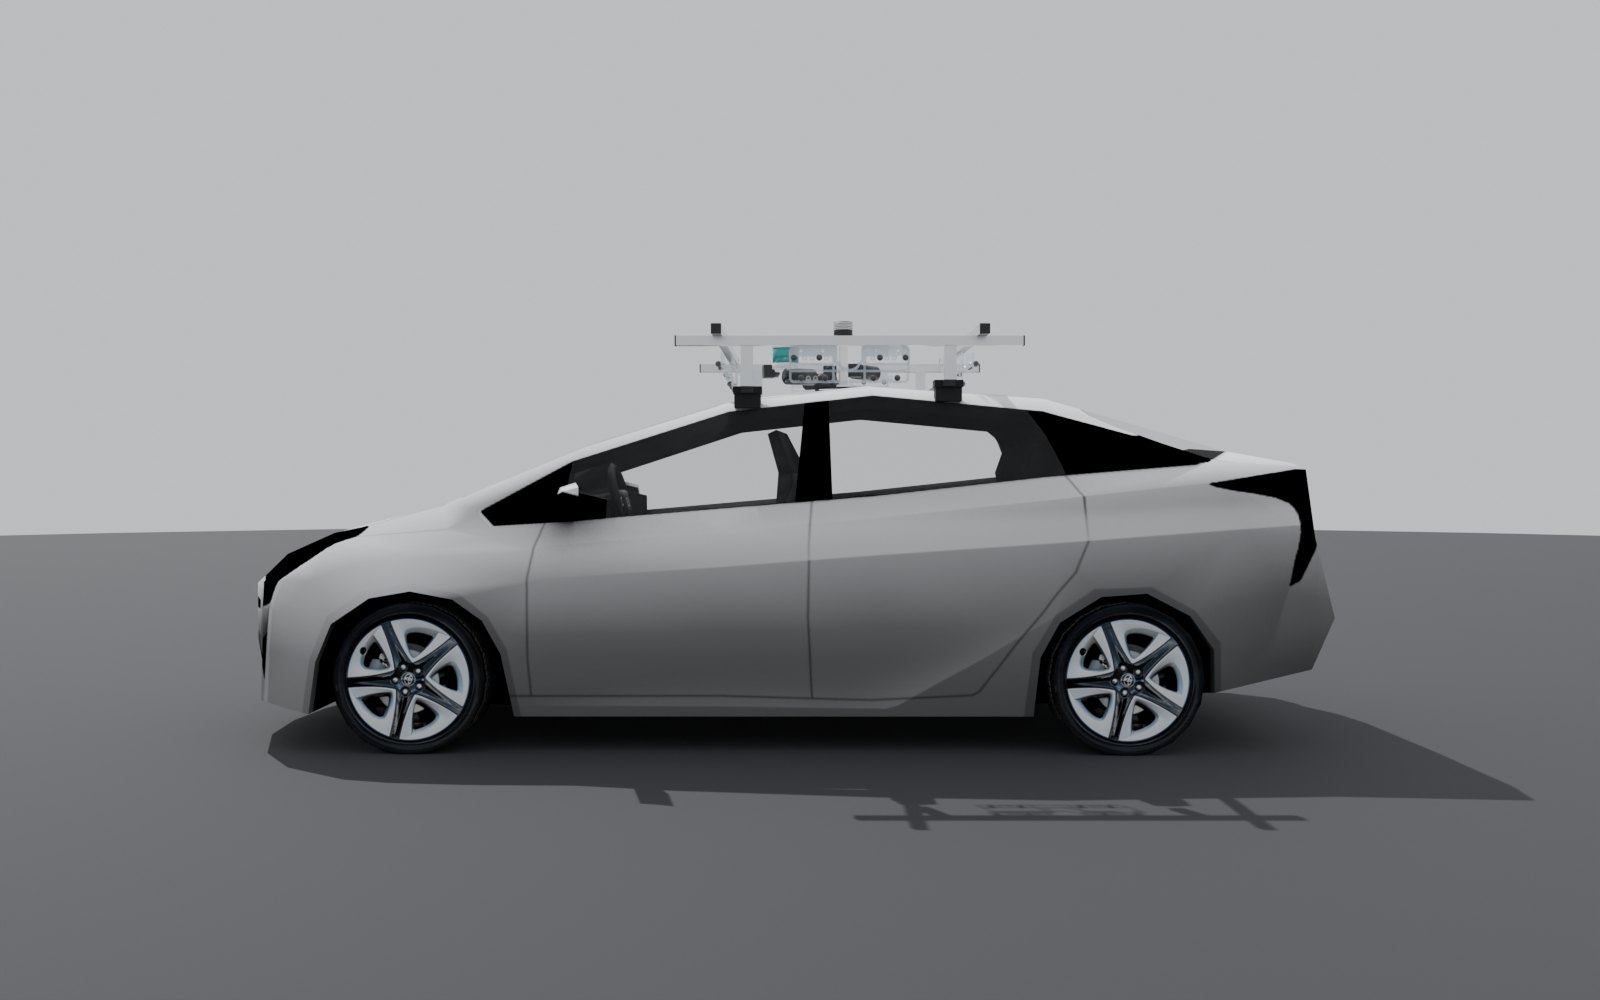
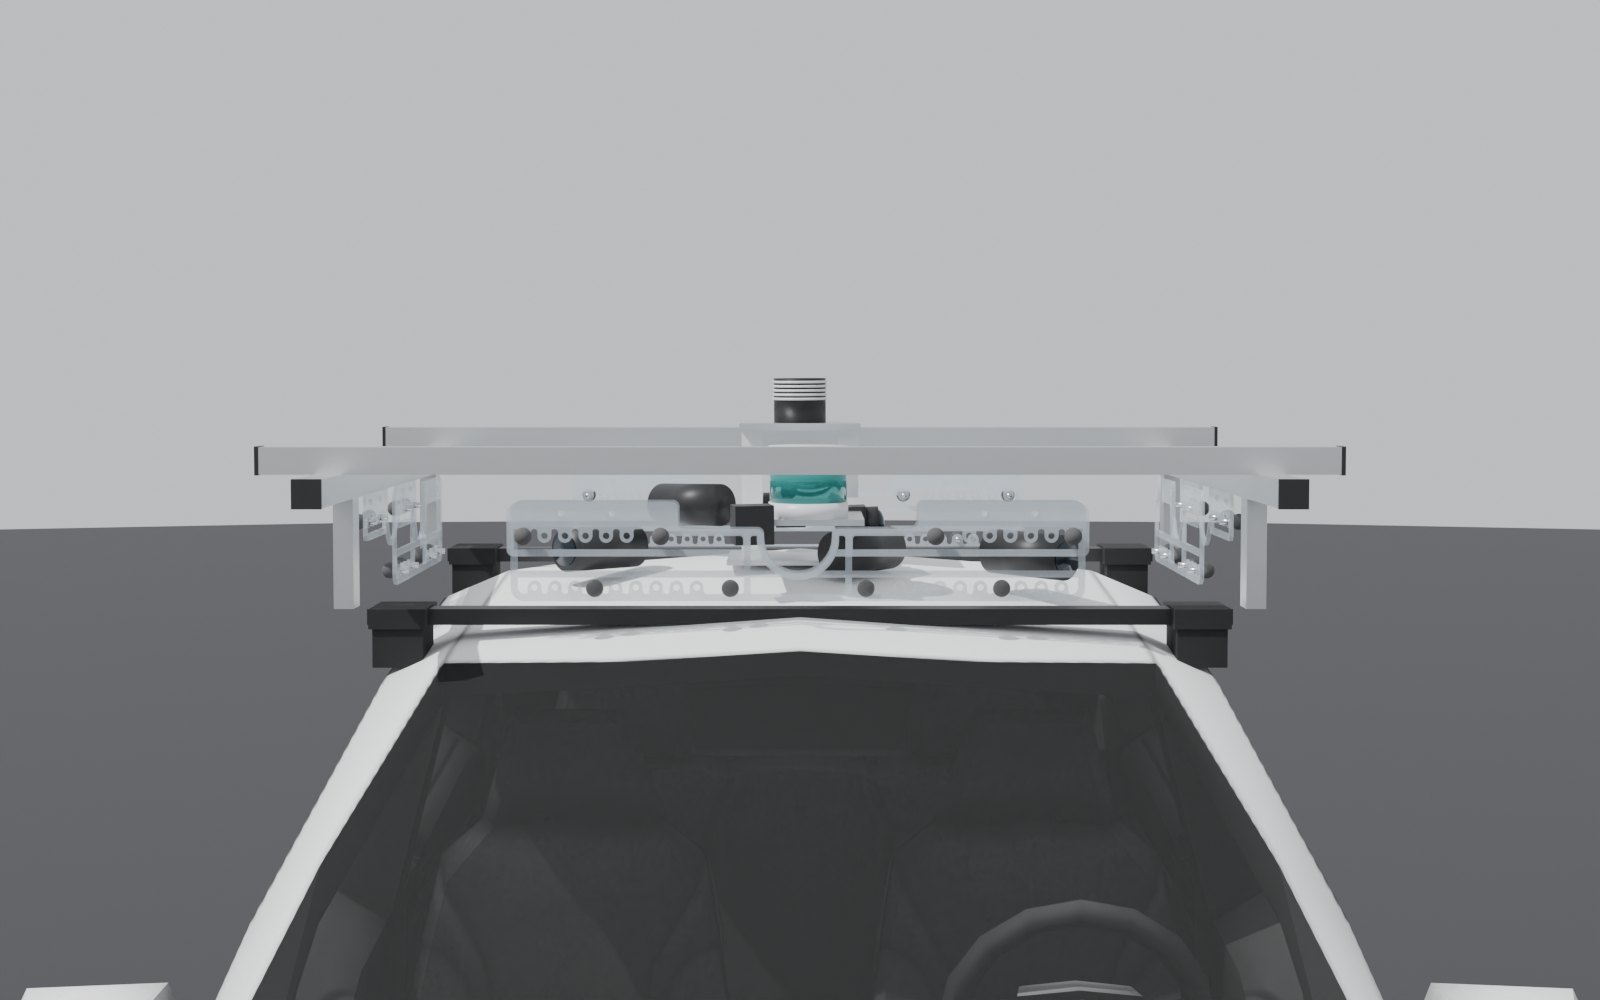
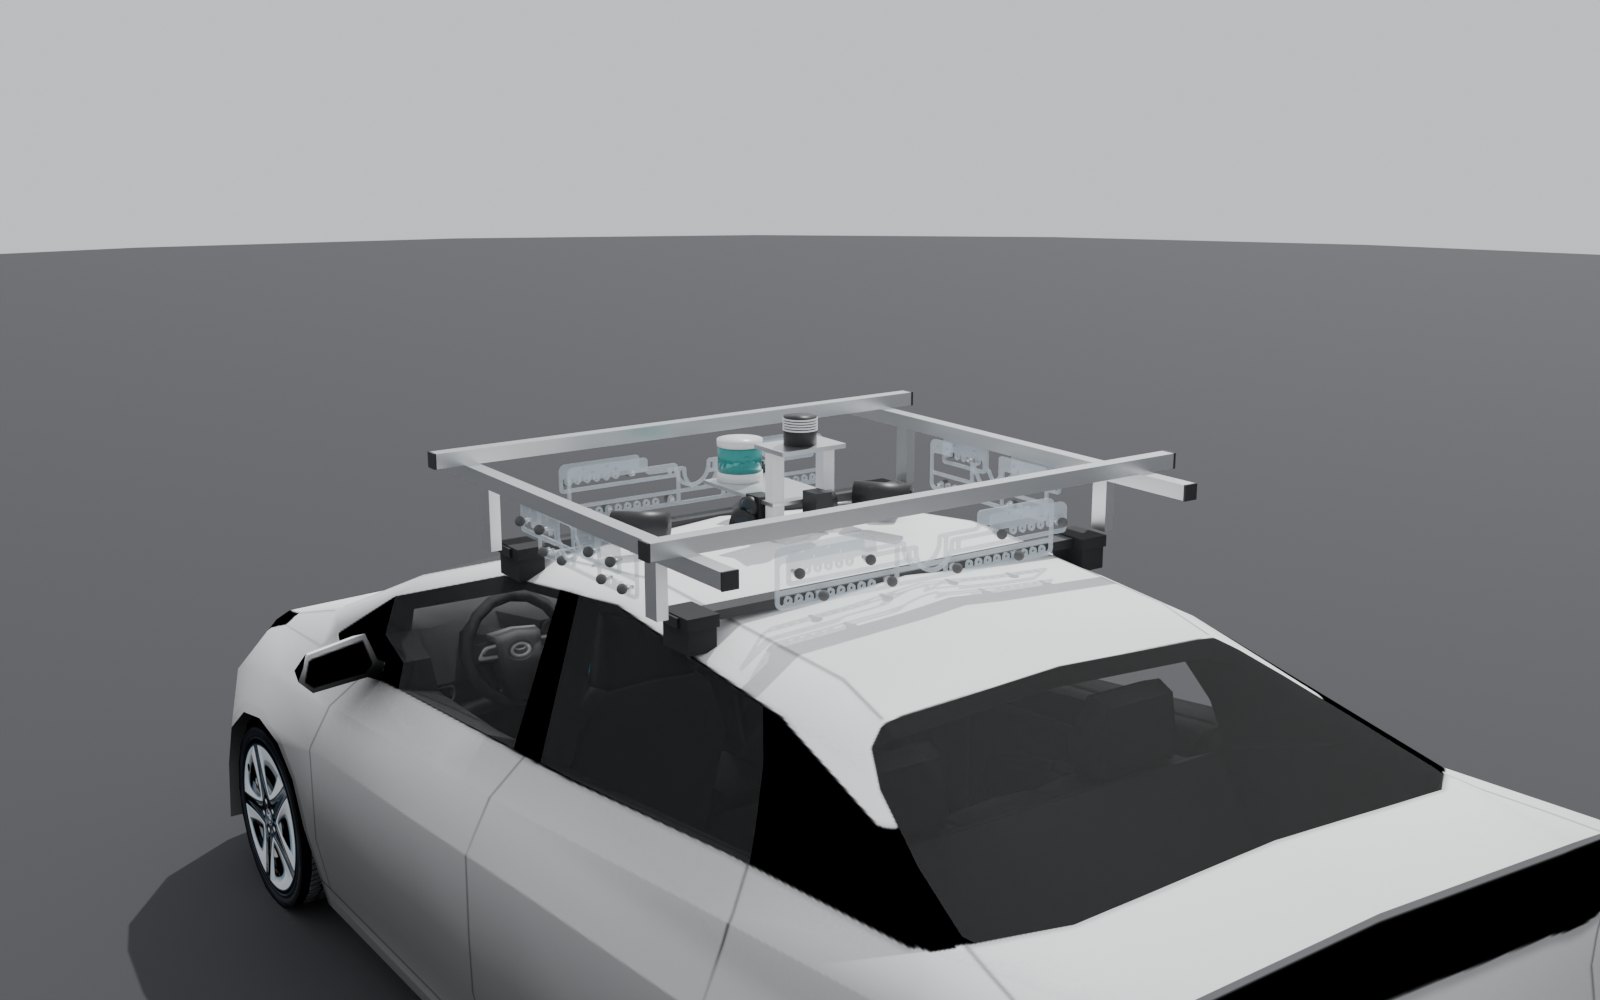
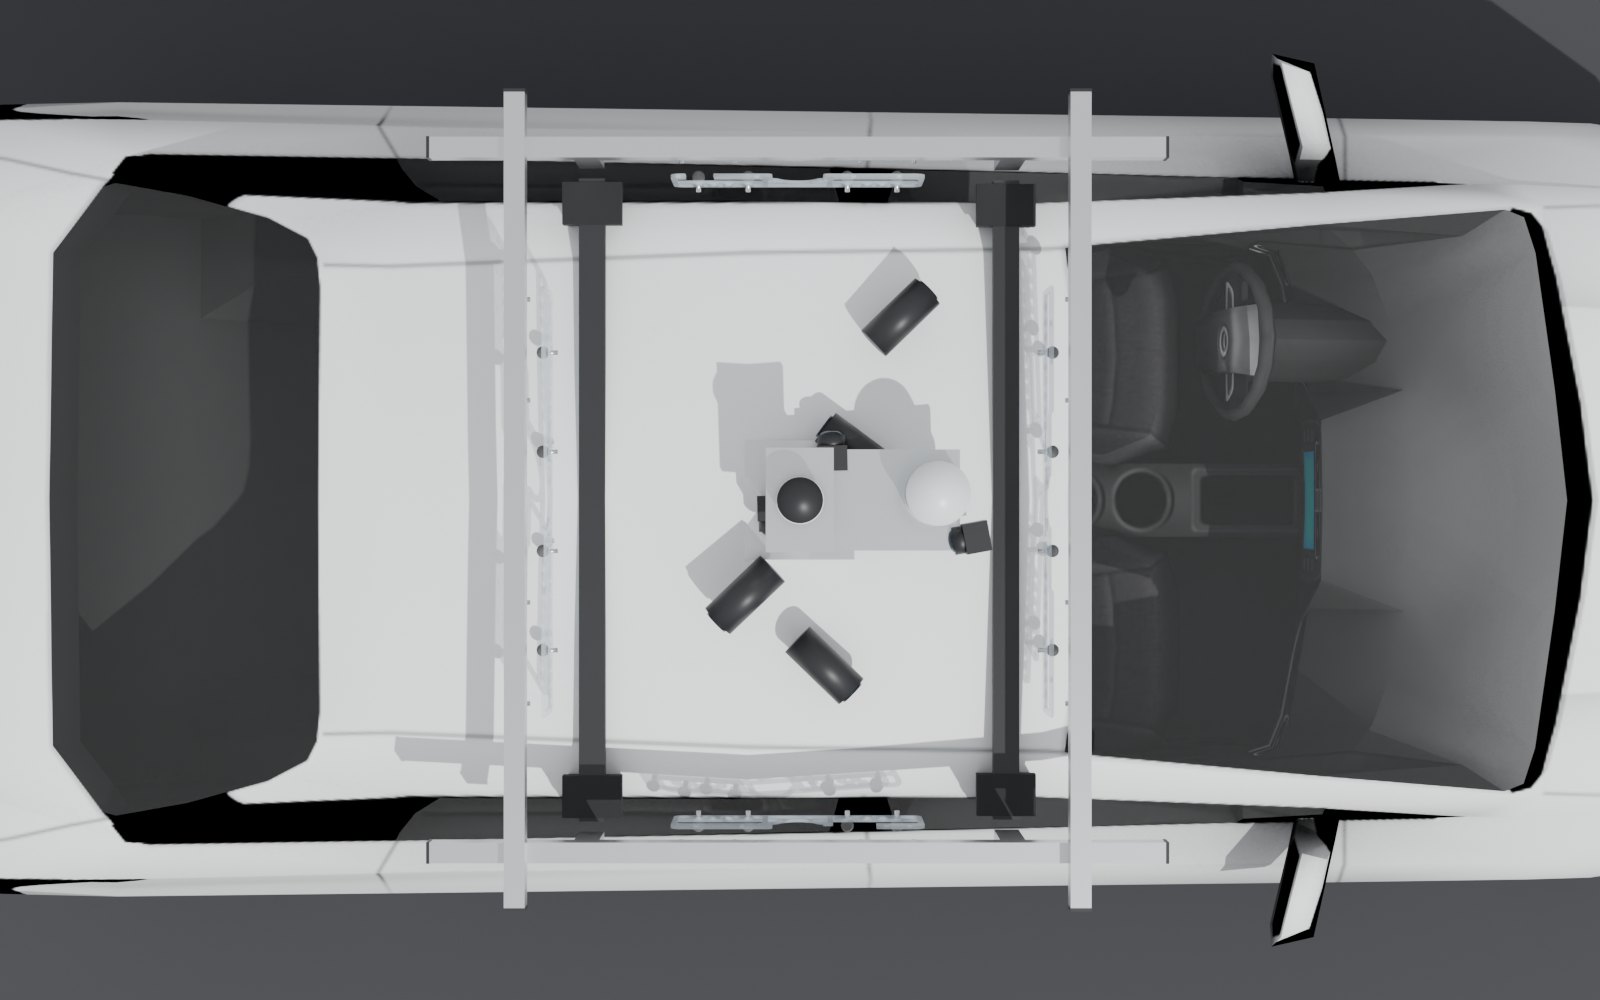
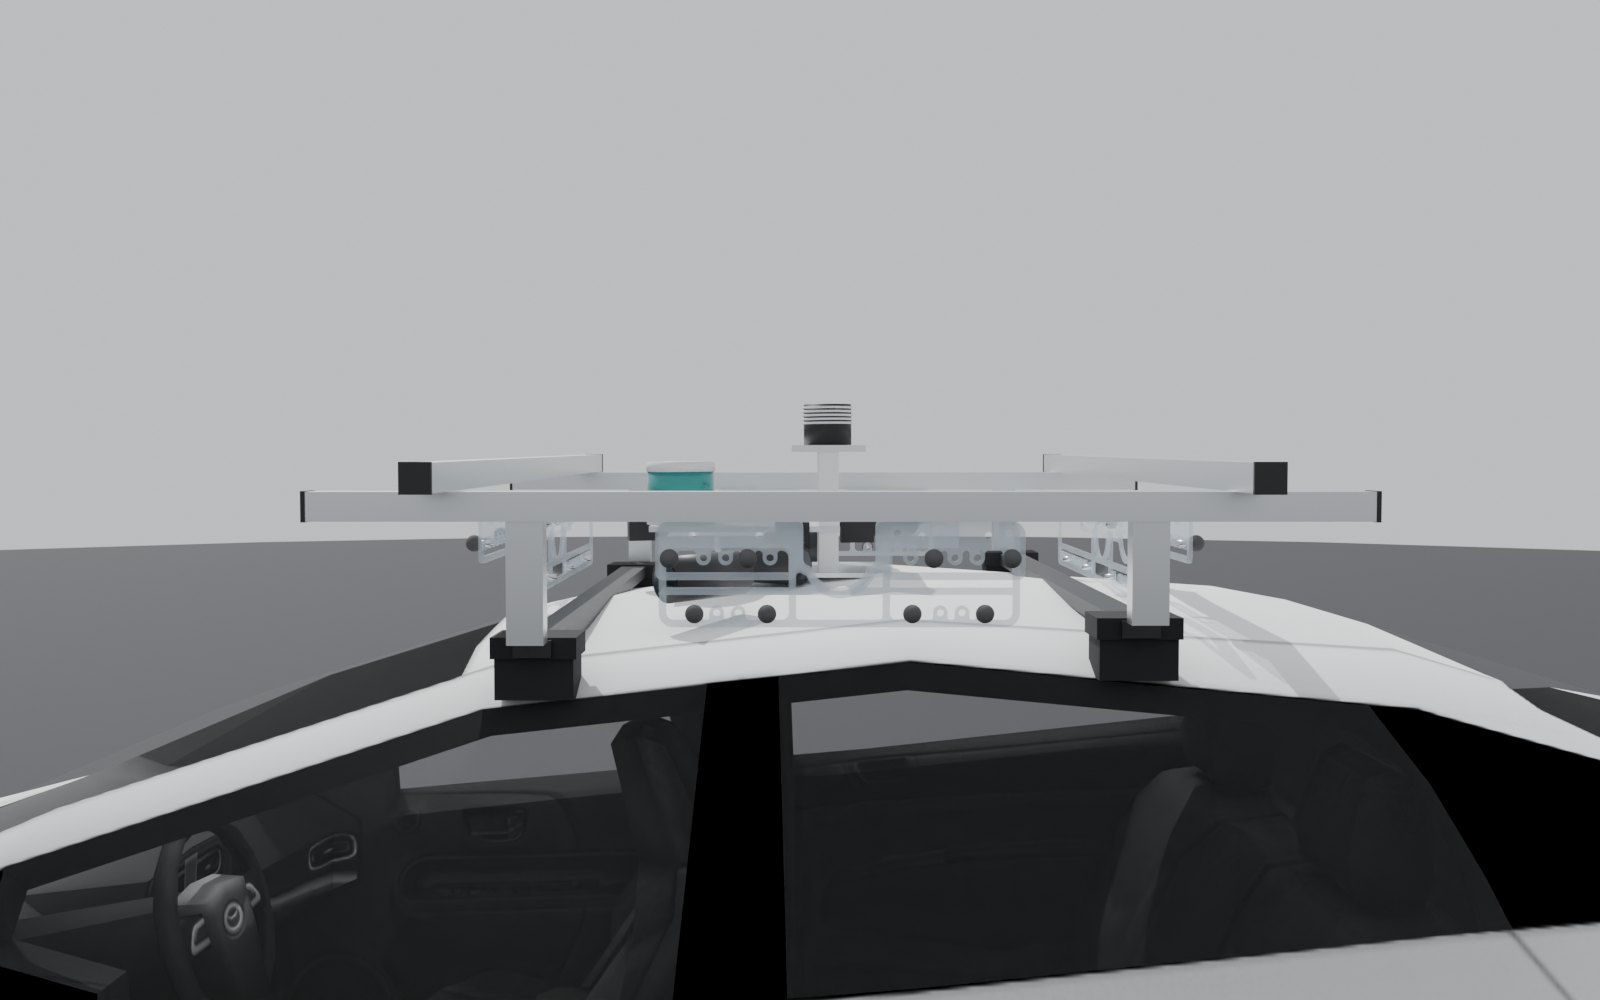
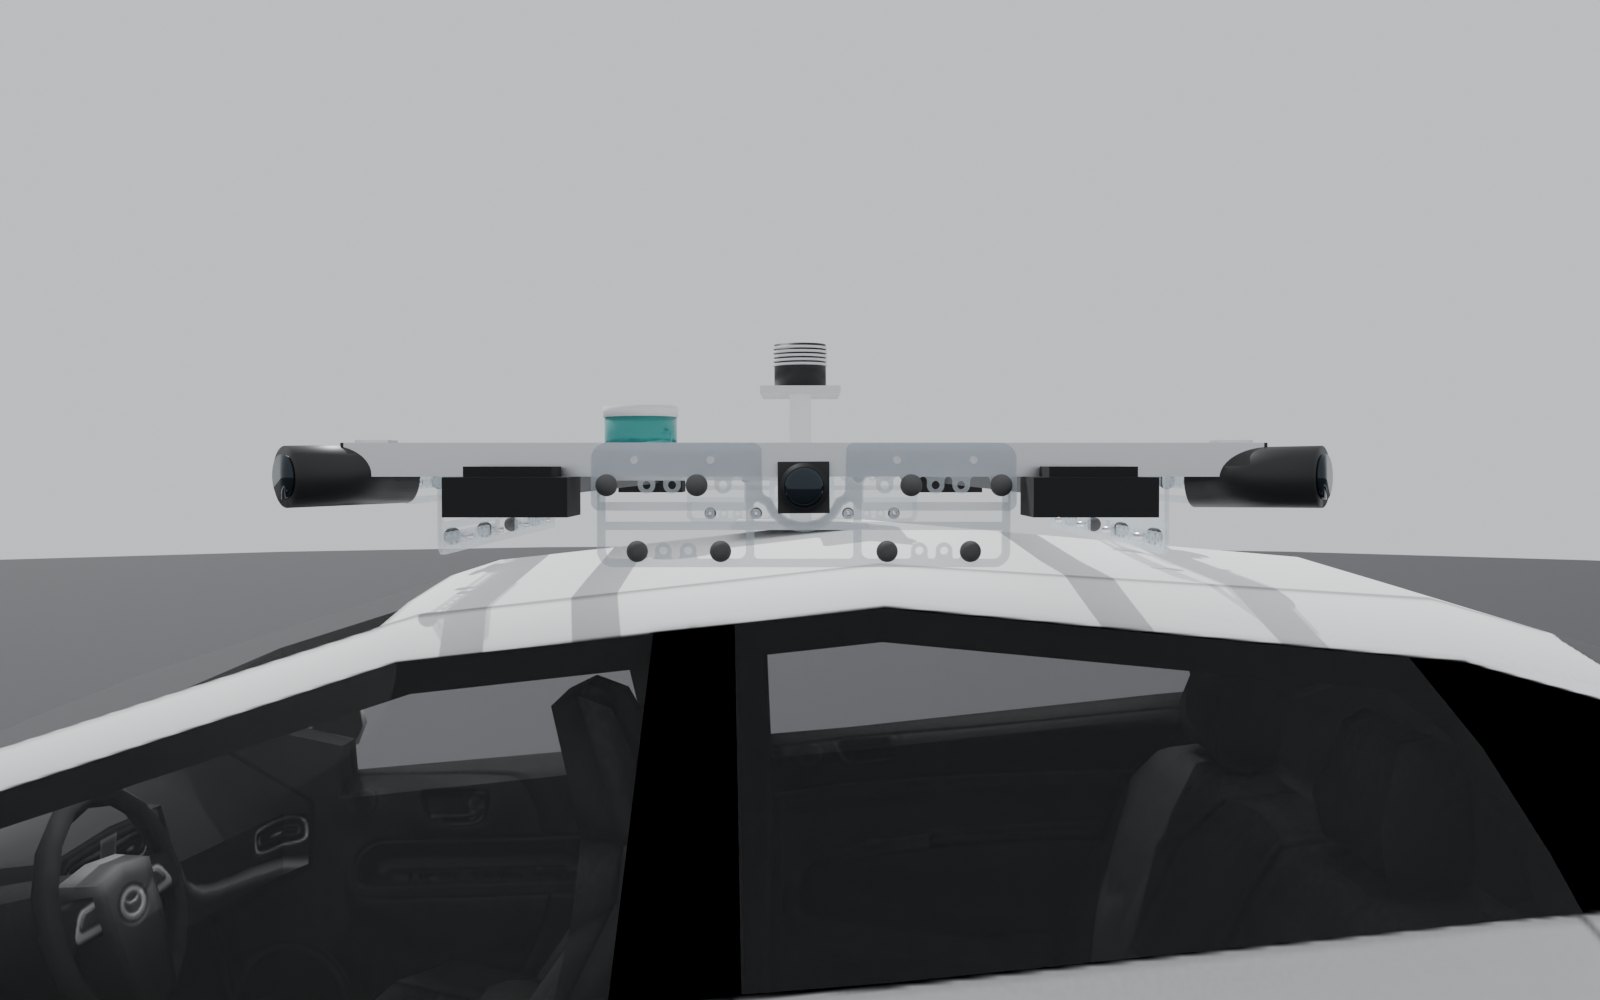
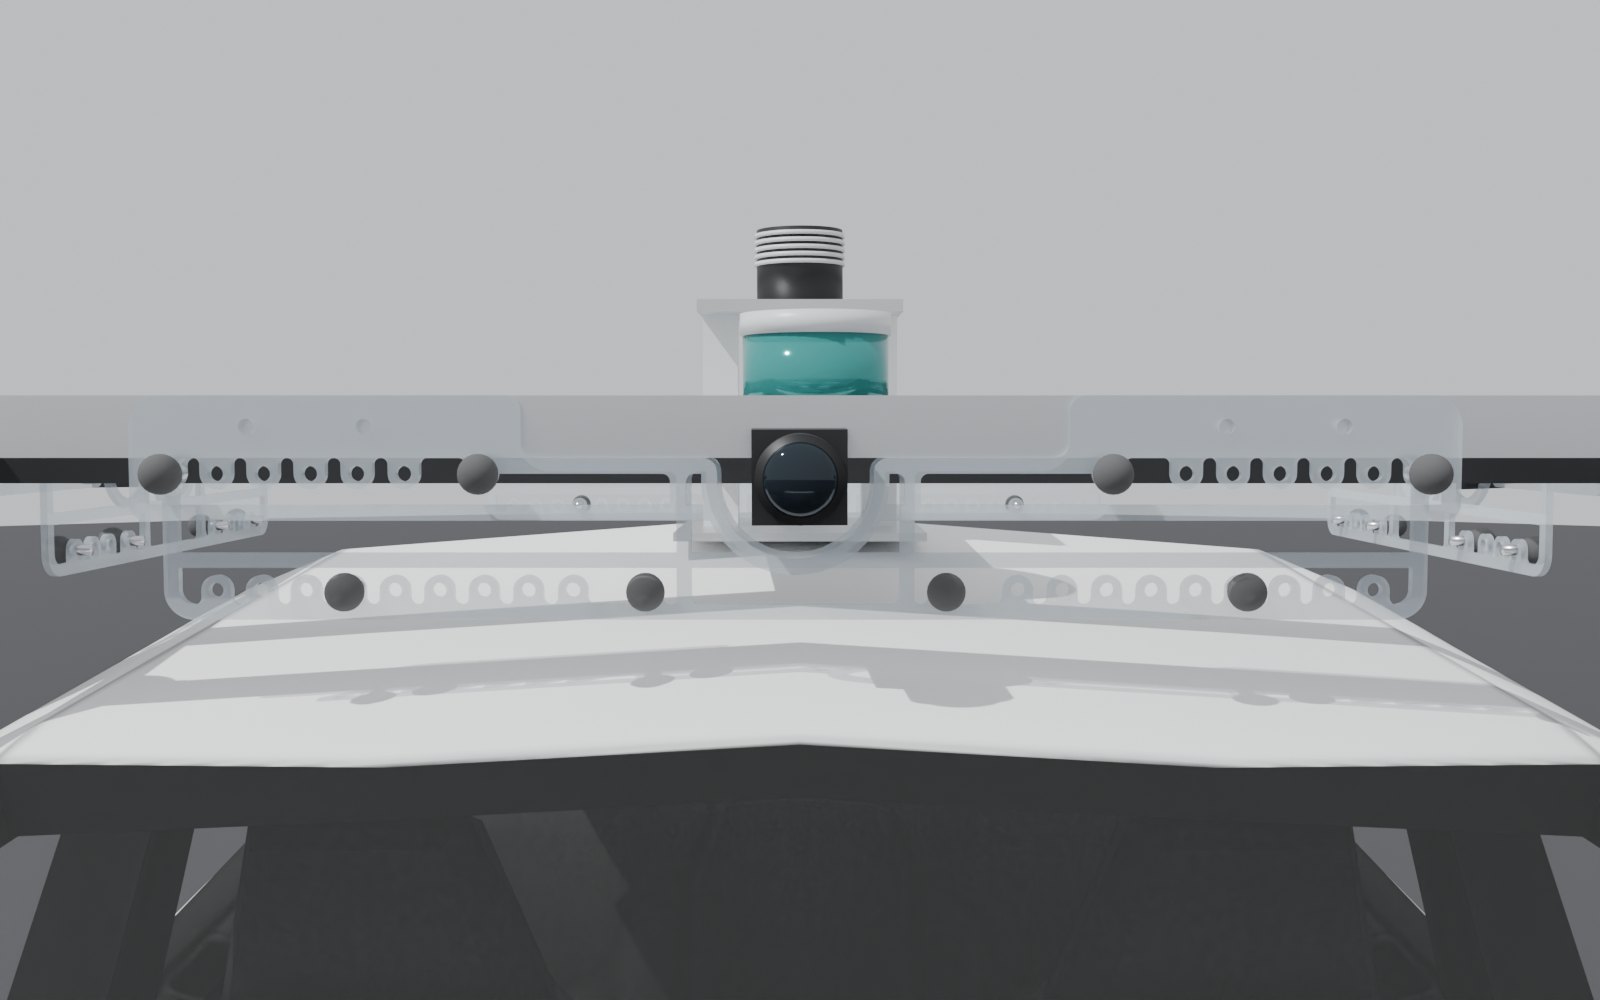
3rd-generation body: this work is based on "Toyota Prius 2012" by Doz3, licensed under CC BY 4.0; changes: repainted white, rescaled to the 2.70 m wheelbase, wheels separated, sensor rig added.